Reading RPLS is free for the whole profession. Members post, reply, and get the members-only rooms.
Notifications
Clear all

Topic starter
Translate
▼
English
Spanish
French
German
Italian
Portuguese
Russian
Chinese
Japanese
Korean
Arabic
Hindi
Dutch
Polish
Turkish
Vietnamese
Thai
Swedish
Danish
Finnish
Norwegian
Czech
Hungarian
Romanian
Greek
Hebrew
Indonesian
Malay
Ukrainian
Bulgarian
Croatian
Slovak
Slovenian
Serbian
Lithuanian
Latvian
Estonian
My father in law used a military system, called PADS. It was big, and rode in a JEEP.
Essentially, it records directions, and time.
Every bump. Every movement.
My dream is to be able to use one of these, with RTK. Get a good clear shot, in the field, to initilize the IMU, then walk to the woods, set it on the monument. Let it settle down. and store the point. Then, walk back to the field, and occupy the SAME or another RTK shot, and you now have a CLOSED LOOP, if every motion, up, down, or sideways is recorded. Somehow, in the back of my mind, they might need a "Backsite" to determine directions.
Now, the longer the loop, the more error is introduced. And, the more time goes by, the more it drifts.
However, it could be cool. And, I think it could be a game changer. But, how accurate are they? What are field procedures?
When I first started reading up on Javad, he had an Umbrella thing, with an IMU.
I wanted one...
Now, it looks like LEICA is coming to market with one. YAY!!
Anytime any mfr comes out with a new, and dynamic product, the Surveyors, and landowners are the winners.
Anybody know anything about these?
Are they accurate?
Can I get any "Hands on" stories?
Thanks!!
Posted : October 5, 2017 2:36 pm

Translate
▼
English
Spanish
French
German
Italian
Portuguese
Russian
Chinese
Japanese
Korean
Arabic
Hindi
Dutch
Polish
Turkish
Vietnamese
Thai
Swedish
Danish
Finnish
Norwegian
Czech
Hungarian
Romanian
Greek
Hebrew
Indonesian
Malay
Ukrainian
Bulgarian
Croatian
Slovak
Slovenian
Serbian
Lithuanian
Latvian
Estonian
Posted : October 5, 2017 4:03 pm

Translate
▼
English
Spanish
French
German
Italian
Portuguese
Russian
Chinese
Japanese
Korean
Arabic
Hindi
Dutch
Polish
Turkish
Vietnamese
Thai
Swedish
Danish
Finnish
Norwegian
Czech
Hungarian
Romanian
Greek
Hebrew
Indonesian
Malay
Ukrainian
Bulgarian
Croatian
Slovak
Slovenian
Serbian
Lithuanian
Latvian
Estonian
I assume it's what's in PIGs. Recently I was shown a PIG plot compared to the GPS locations and it was amazing how accurate it was. And it went for 60 miles or so, how it's set-up I don't know, they must be somehow reset at the launcher. I do know they aren't cheap.
Posted : October 5, 2017 4:07 pm

Translate
▼
English
Spanish
French
German
Italian
Portuguese
Russian
Chinese
Japanese
Korean
Arabic
Hindi
Dutch
Polish
Turkish
Vietnamese
Thai
Swedish
Danish
Finnish
Norwegian
Czech
Hungarian
Romanian
Greek
Hebrew
Indonesian
Malay
Ukrainian
Bulgarian
Croatian
Slovak
Slovenian
Serbian
Lithuanian
Latvian
Estonian
Smart pigs use a AGM which is a monument set at ground level on top off the pipe. You can put a box that has a clock built in on top of the monument. When the pig goes by it triggers a spike in the computer inside the pig. They use the multiple clocks set at maybe 5 mile intervals to control the speed . The AGM'S must help tie the pigs route to the pipeline route.
Posted : October 6, 2017 12:57 pm

Translate
▼
English
Spanish
French
German
Italian
Portuguese
Russian
Chinese
Japanese
Korean
Arabic
Hindi
Dutch
Polish
Turkish
Vietnamese
Thai
Swedish
Danish
Finnish
Norwegian
Czech
Hungarian
Romanian
Greek
Hebrew
Indonesian
Malay
Ukrainian
Bulgarian
Croatian
Slovak
Slovenian
Serbian
Lithuanian
Latvian
Estonian
I also know someone that was in the military that used something similar and he said it rode in a Hummer it was so large. I assume its some kind of gyro system but don't know.
Posted : October 6, 2017 1:01 pm

Translate
▼
English
Spanish
French
German
Italian
Portuguese
Russian
Chinese
Japanese
Korean
Arabic
Hindi
Dutch
Polish
Turkish
Vietnamese
Thai
Swedish
Danish
Finnish
Norwegian
Czech
Hungarian
Romanian
Greek
Hebrew
Indonesian
Malay
Ukrainian
Bulgarian
Croatian
Slovak
Slovenian
Serbian
Lithuanian
Latvian
Estonian
I've used both the Applanix POS, and the ZUPT back packs. Great for staking rough line in heavy canopy if you can live with 10-15' horizontal error in a mile. Post processed lines come in about 1/3 of that. These are used extensively in the twitterbugging world.
Posted : October 9, 2017 11:50 am

Translate
▼
English
Spanish
French
German
Italian
Portuguese
Russian
Chinese
Japanese
Korean
Arabic
Hindi
Dutch
Polish
Turkish
Vietnamese
Thai
Swedish
Danish
Finnish
Norwegian
Czech
Hungarian
Romanian
Greek
Hebrew
Indonesian
Malay
Ukrainian
Bulgarian
Croatian
Slovak
Slovenian
Serbian
Lithuanian
Latvian
Estonian
Tim Reed, post: 450154, member: 420 wrote: in the twitterbugging world.
What is this?
Posted : October 9, 2017 11:53 am
Translate
▼
English
Spanish
French
German
Italian
Portuguese
Russian
Chinese
Japanese
Korean
Arabic
Hindi
Dutch
Polish
Turkish
Vietnamese
Thai
Swedish
Danish
Finnish
Norwegian
Czech
Hungarian
Romanian
Greek
Hebrew
Indonesian
Malay
Ukrainian
Bulgarian
Croatian
Slovak
Slovenian
Serbian
Lithuanian
Latvian
Estonian
Twitterbugs / AKA Geophysical Seismic Exploration guys.
Posted : October 9, 2017 12:56 pm

Translate
▼
English
Spanish
French
German
Italian
Portuguese
Russian
Chinese
Japanese
Korean
Arabic
Hindi
Dutch
Polish
Turkish
Vietnamese
Thai
Swedish
Danish
Finnish
Norwegian
Czech
Hungarian
Romanian
Greek
Hebrew
Indonesian
Malay
Ukrainian
Bulgarian
Croatian
Slovak
Slovenian
Serbian
Lithuanian
Latvian
Estonian
Tim Reed, post: 450163, member: 420 wrote: Twitterbugs / AKA Geophysical Seismic Exploration guys.
Times have changed. We use to call them doodlebugs.
Posted : October 9, 2017 1:05 pm

Translate
▼
English
Spanish
French
German
Italian
Portuguese
Russian
Chinese
Japanese
Korean
Arabic
Hindi
Dutch
Polish
Turkish
Vietnamese
Thai
Swedish
Danish
Finnish
Norwegian
Czech
Hungarian
Romanian
Greek
Hebrew
Indonesian
Malay
Ukrainian
Bulgarian
Croatian
Slovak
Slovenian
Serbian
Lithuanian
Latvian
Estonian
Posted : October 11, 2017 9:54 pm

Translate
▼
English
Spanish
French
German
Italian
Portuguese
Russian
Chinese
Japanese
Korean
Arabic
Hindi
Dutch
Polish
Turkish
Vietnamese
Thai
Swedish
Danish
Finnish
Norwegian
Czech
Hungarian
Romanian
Greek
Hebrew
Indonesian
Malay
Ukrainian
Bulgarian
Croatian
Slovak
Slovenian
Serbian
Lithuanian
Latvian
Estonian
I know I heard of IMU surveying by helicopter teams in Alaska., but that was a long time ago.... why would you want to use old technology to get bad data??
Posted : October 12, 2017 5:14 am

Translate
▼
English
Spanish
French
German
Italian
Portuguese
Russian
Chinese
Japanese
Korean
Arabic
Hindi
Dutch
Polish
Turkish
Vietnamese
Thai
Swedish
Danish
Finnish
Norwegian
Czech
Hungarian
Romanian
Greek
Hebrew
Indonesian
Malay
Ukrainian
Bulgarian
Croatian
Slovak
Slovenian
Serbian
Lithuanian
Latvian
Estonian
Andy J, post: 450596, member: 44 wrote: I know I heard of IMU surveying by helicopter teams in Alaska., but that was a long time ago.... why would you want to use old technology to get bad data??
IMU isn't the sole measurement source in this instance, it seems it is constantly providing data along with the GNSS to store a measurement. I have seen quite a few pictures floating around of angled pole measurements on known control with accuracy in the 0.02'-0.06' range. Pretty impressive technology released by Leica.
Posted : October 12, 2017 5:43 am

Translate
▼
English
Spanish
French
German
Italian
Portuguese
Russian
Chinese
Japanese
Korean
Arabic
Hindi
Dutch
Polish
Turkish
Vietnamese
Thai
Swedish
Danish
Finnish
Norwegian
Czech
Hungarian
Romanian
Greek
Hebrew
Indonesian
Malay
Ukrainian
Bulgarian
Croatian
Slovak
Slovenian
Serbian
Lithuanian
Latvian
Estonian
[USER=444]@Jules J.[/USER]
When I was a kid we used to call "Ant Lions" doodle bugs and spent hours throwing ants in their traps.
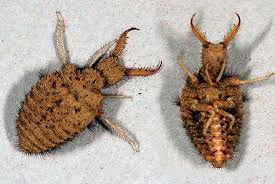
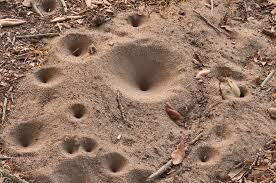
They didn't have video games back then just black and white TV, (with THREE channels) so we amused ourselves by playing outside from dawn to dusk climbing trees, playing baseball, riding bikes, fishing, and all of those now unheard of activities. 😉
Posted : October 12, 2017 6:05 am

Translate
▼
English
Spanish
French
German
Italian
Portuguese
Russian
Chinese
Japanese
Korean
Arabic
Hindi
Dutch
Polish
Turkish
Vietnamese
Thai
Swedish
Danish
Finnish
Norwegian
Czech
Hungarian
Romanian
Greek
Hebrew
Indonesian
Malay
Ukrainian
Bulgarian
Croatian
Slovak
Slovenian
Serbian
Lithuanian
Latvian
Estonian
We called them "mudbuggers".
Posted : October 14, 2017 10:43 pm

Translate
▼
English
Spanish
French
German
Italian
Portuguese
Russian
Chinese
Japanese
Korean
Arabic
Hindi
Dutch
Polish
Turkish
Vietnamese
Thai
Swedish
Danish
Finnish
Norwegian
Czech
Hungarian
Romanian
Greek
Hebrew
Indonesian
Malay
Ukrainian
Bulgarian
Croatian
Slovak
Slovenian
Serbian
Lithuanian
Latvian
Estonian
Tagging for later.
Posted : October 14, 2017 11:28 pm

Translate
▼
English
Spanish
French
German
Italian
Portuguese
Russian
Chinese
Japanese
Korean
Arabic
Hindi
Dutch
Polish
Turkish
Vietnamese
Thai
Swedish
Danish
Finnish
Norwegian
Czech
Hungarian
Romanian
Greek
Hebrew
Indonesian
Malay
Ukrainian
Bulgarian
Croatian
Slovak
Slovenian
Serbian
Lithuanian
Latvian
Estonian
Andy J, post: 450596, member: 44 wrote: I know I heard of IMU surveying by helicopter teams in Alaska., but that was a long time ago.... why would you want to use old technology to get bad data??
Andy, in the aerial mapping business we fly with integrated GNSS/IMU's on each sensor (camera, LiDAR, etc.). About 1/2 my work these days is post processing the trajectory, greatly enhances the downstream mapping processes and reduces ground control by at least a factor of two.
The IMU and GNSS complement each other, the IMU is typically recording data at 200 Hz and the GNSS at 2 hz, the two data sets align to each other and we typically achieve very good results, in fact this trajectory alone on our LiDAR flights processing with PPP (no ground control at all) produces agreement with check shots at the 0.1 foot level, obviously NOT the same as 20 year old technology. Of course we usually add ground control and adjust to it.
SHG
Posted : October 19, 2017 3:48 pm
Translate
▼
English
Spanish
French
German
Italian
Portuguese
Russian
Chinese
Japanese
Korean
Arabic
Hindi
Dutch
Polish
Turkish
Vietnamese
Thai
Swedish
Danish
Finnish
Norwegian
Czech
Hungarian
Romanian
Greek
Hebrew
Indonesian
Malay
Ukrainian
Bulgarian
Croatian
Slovak
Slovenian
Serbian
Lithuanian
Latvian
Estonian
Shelby H. Griggs PLS, post: 451709, member: 335 wrote: Andy, in the aerial mapping business we fly with integrated GNSS/IMU's on each sensor (camera, LiDAR, etc.). About 1/2 my work these days is post processing the trajectory, greatly enhances the downstream mapping processes and reduces ground control by at least a factor of two.
The IMU and GNSS complement each other, the IMU is typically recording data at 200 Hz and the GNSS at 2 hz, the two data sets align to each other and we typically achieve very good results, in fact this trajectory alone on our LiDAR flights processing with PPP (no ground control at all) produces agreement with check shots at the 0.1 foot level, obviously NOT the same as 20 year old technology. Of course we usually add ground control and adjust to it.
SHG
Thanks, I had no idea that technology was even in use. Seems a long way from the stories I heard of gangs of helicopters tossing bags with powder out for targets to hover over!
Posted : October 20, 2017 5:27 am